Microphone Array Localization
A MATLAB reconstruction and modernization of an academic two-dimensional sound-source localization simulation.
Overview
A public technical and academic project with a published v1.0.0 portfolio release and reproducible simulation results.
Problem / motivation
Time-difference-of-arrival estimators need a clear, deterministic simulation harness for comparison and verification.
What it implements
- Simulate one stationary synthetic source in a synchronized, direct-path two-dimensional environment.
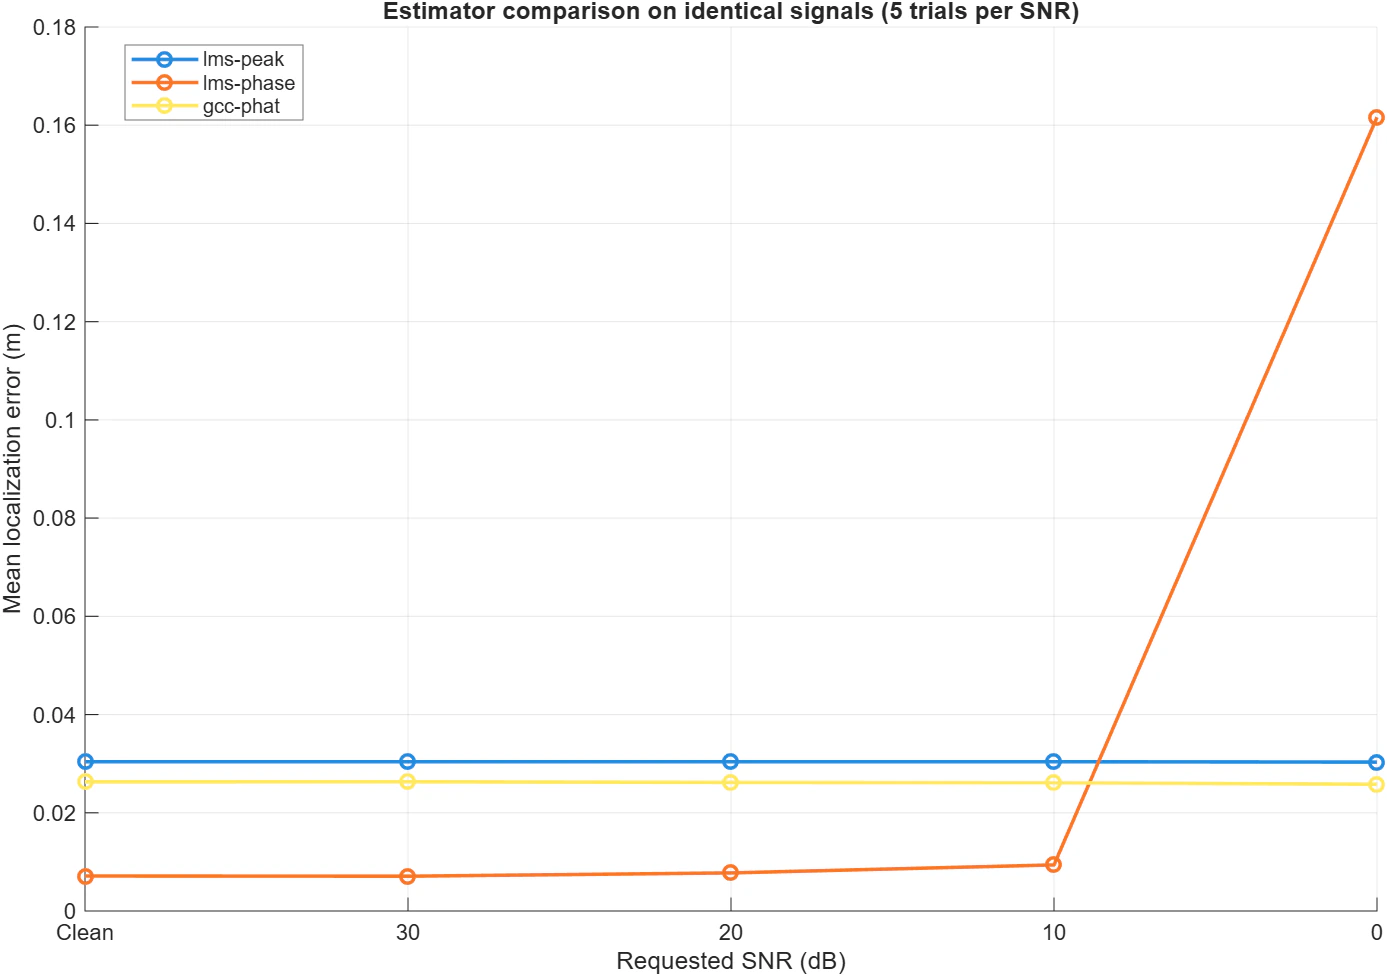
- Compare LMS peak, LMS phase-slope and independently implemented GCC-PHAT estimators.
- Use deterministic MATLAB tests and reproducible figures to document selected simulation scenarios.
Architecture / workflow
- A shared configuration defines a synchronized two-dimensional direct-path simulation and stationary synthetic source.
- LMS peak, LMS phase-slope and independently implemented GCC-PHAT estimators process comparable simulated signals.
- The result workflow produces deterministic figures for estimator comparison and selected signal-to-noise conditions.
Key engineering decisions
Bound the scientific claim
Results are described as reproducible simulation outcomes, not general real-world accuracy or production performance.
Multiple estimators behind one workflow
A shared configuration and result structure makes estimator behaviour easier to compare.
Reliability / scientific boundaries
- Deterministic configuration keeps repeated simulation runs explainable and comparable.
- Every result is labelled as simulated output rather than field validation or production acoustic performance.
- A published release fixes the reviewed v1.0.0 project state represented here.
Validation / testing
- Deterministic MATLAB tests exercise the selectable estimator workflow.
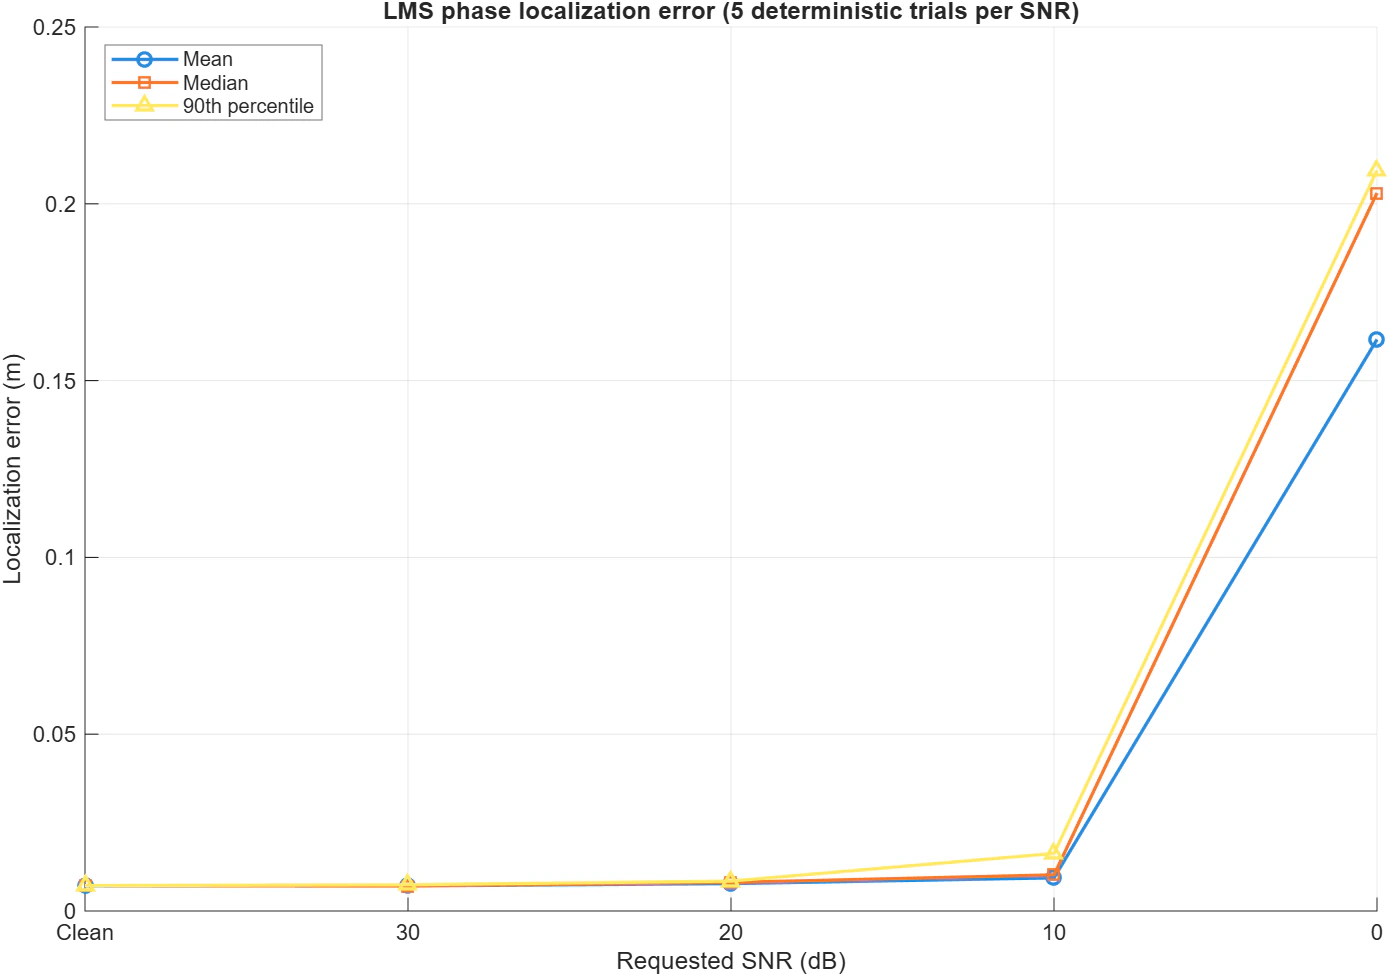
- Reproducible figures compare estimators on identical synthetic inputs and selected SNR scenarios.
- The public v1.0.0 release provides a stable reference for the published results.
Project evidence
Screenshots / results
Verified output from Microphone Array Localization, presented with the operating boundaries described on this page.
Outcomes
- Published a tested v1.0.0 release with selectable estimators and reproducible documentation figures.
Current scope / limitations
The project evaluates selected synchronized, direct-path, two-dimensional synthetic scenarios. The figures are reproducible simulation results and are not claims of general real-world localization accuracy.